The chapter
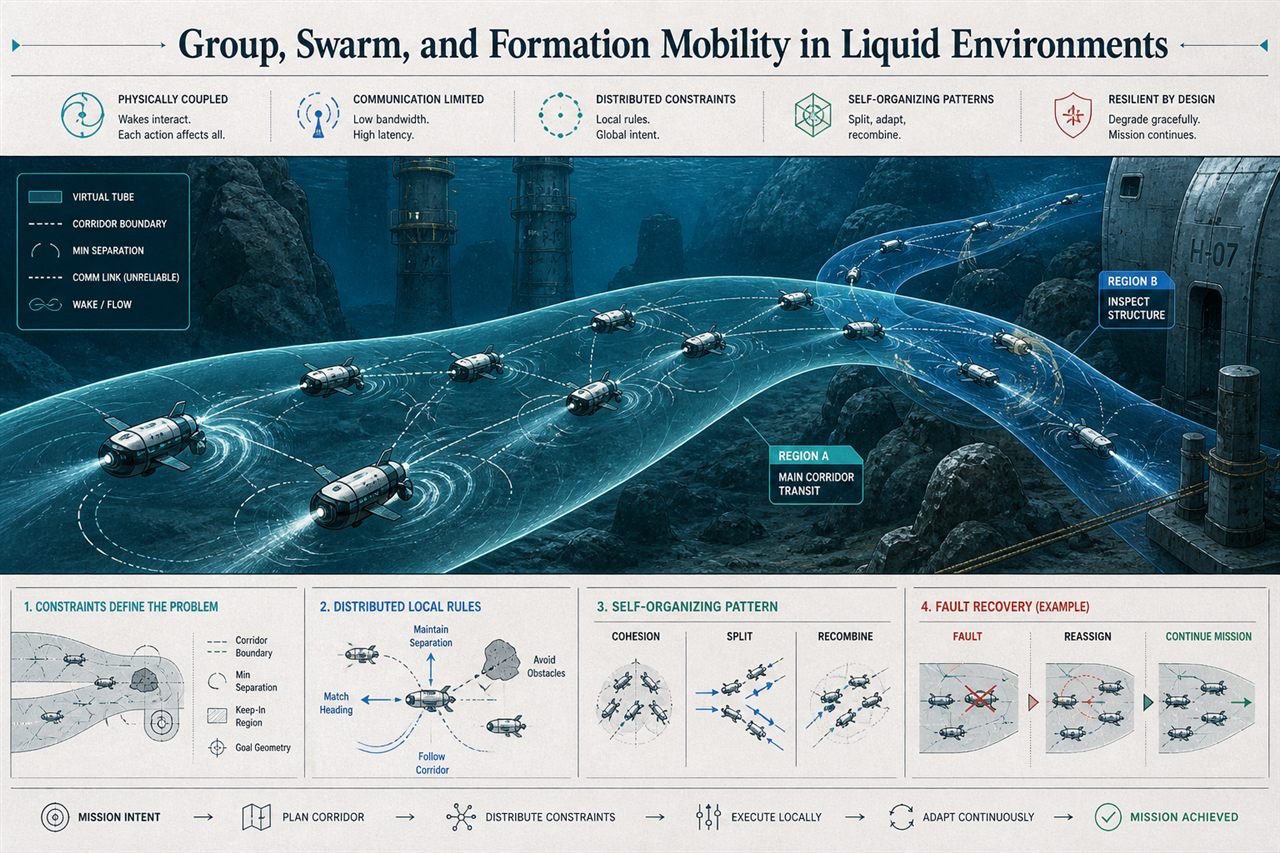
Coordinated mobility for multiple underwater or fluid-adapted vehicles depends on maintaining formation geometry, avoiding collisions, allocating tasks, and recovering from failures despite hydrodynamic coupling, degraded sensing, and low-bandwidth, high-latency links. As of 2026, strong evidence exists for key transferable swarm primitives—constraint-coordination and distributed optimization for dense formations, rapid self-organizing patterns for partitioned spaces, and virtual-tube planning for safe corridors in clutter. Direct peer-reviewed validation for true underwater multi-vehicle swarms remains limited, so near-term strategy should focus on adapting these proven methods and validating them in marine field operations, with governance and interoperability standards in mind.
This record lists the chapter's canonical sources and its revisions as recorded on Comuvia's BookWriter and MediaManager systems. The chapter and its video are AI-authored and AI-produced; the sources ground the text, they do not endorse it.
Sources
The chapter's canonical source pack as recorded on BookWriter: milestone papers, patents and news found through Crossref, OpenAlex, USPTO and news providers. Tier reflects citation strength, not Comuvia's endorsement.
| # | Type | Source | Tier | Found via |
|---|---|---|---|---|
| 1 | Paper | Evolutionary-Group-Based Particle-Swarm-Optimized Fuzzy Controller With Application to Mobile-Robot Navigation in Unknown Environments Juang, Chia-Feng et al. · IEEE Transactions on Fuzzy Systems · 2011 · doi:10.1109/tfuzz.2011.2104364 | gold · highly cited | crossref |
| 2 | Paper | Fielded Human-Robot Interaction for a Heterogeneous Team in the DARPA Subterranean Challenge Riley, Danny G. et al. · ACM Transactions on Human-Robot Interaction · 2023 · doi:10.1145/3588325 | gold · highly cited | crossref |
| 3 | Paper | Watch a swarm of drones fly through heavy forest—while staying in formation Gent, Edd · Science · 2020 · doi:10.1126/science.abg1975 | gold · highly cited | crossref |
| 4 | Paper | An Application of Swarm Robotics in Architectural Design Yiannoudes Socrates · Ambient Intelligence and Smart Environments · 2009 · doi:10.3233/978-1-60750-034-6-362 | strong | crossref |
| 5 | Paper | A swarm model with constraint coordination mechanism for unmanned aerial vehicle swarm formation maintenance in dense environments Xiong, Hui et al. · Industrial Robot: the international journal of robotics research and application · 2024 · doi:10.1108/ir-07-2024-0316 | strong | crossref |
| 6 | Paper | Pattern formation in constrained environments: A swarm robot target trapping method Peng, Xingguang et al. · 2016 International Conference on Advanced Robotics and Mechatronics (ICARM) · 2016 · doi:10.1109/icarm.2016.7606963 | strong | crossref |
| 7 | Paper | DoViT-Swarm: A Lightweight Dynamic Optimal Virtual Tube Planner for Swarm Aerial Robotics in Cluttered Environments Wang, Pengxiao et al. · IEEE Robotics and Automation Letters · 2026 · doi:10.1109/lra.2026.3688103 | strong | crossref |
| 8 | Paper | Visions of Process—Swarm Intelligence and Swarm Robotics in Architectural Design and Construction Vehlken, Sebastian · Springer Series in Adaptive Environments · 2018 · doi:10.1007/978-3-319-70866-9_1 | strong | crossref |
| 9 | Paper | Evaluating Swarm Robotics for Diverse Mining Environments: Insights into Model Performance and Application Tan, Joven et al. · 2024 · doi:10.20944/preprints202408.0410.v1 | strong | crossref |
| 10 | Paper | A Fast Self-Organizing Pattern Formation Method for Swarm Robots in Dynamic Multi-Region Environments Wang, Qiuzhen et al. · 2020 5th International Conference on Automation, Control and Robotics Engineering (CACRE) · 2020 · doi:10.1109/cacre50138.2020.9230325 | strong | crossref |
| 11 | Paper | Distributed Swarm Trajectory Optimization for Formation Flight in Dense Environments Quan, Lun et al. · 2022 International Conference on Robotics and Automation (ICRA) · 2022 · doi:10.1109/icra46639.2022.9812050 | strong | crossref |
| 12 | Paper | Parallel Clustered Particle Swarm Optimization in Mobile Environments International Journal of Recent Trends in Engineering and Research · 2017 · doi:10.23883/ijrter.2017.3310.4rkn1 | strong | crossref |
Revisions
| When | Event | Detail |
|---|---|---|
| May 5, 2026 | Source pack version | version 1 · refresh coverage gap · 12 entries |
| May 6, 2026 | Source check | pass · coverage 75 % |
| Aug 2, 2026 | Published on the channel | upload date as listed on the channel · KY_cGinBEyw |
About this record
Book: The Long Horizon: A Vision of Frontier Technology from 2026 to 2400 (BookWriter (Comuvia S2)). Channel: Comuvia Vision. Sources are the chapter's canonical source pack in BookWriter (milestone papers, patents and news found through Crossref, OpenAlex, USPTO and news providers; tiers gold/strong by citation strength); revisions are the pack versions, the compliance checks and the campaign's uploads. The chapter text itself is AI-authored on BookWriter; the sources ground it, they do not endorse it.
anchor aa106fef-58ff-4fa3-ab99-b2e66d06bbc4 · thread b8d9b63f-e8e1-4022-91e1-d1b50eea1afa